Solutions
Autonomous robotics, from the ground station to the edge
Software and robotic platforms, modular and built on open-source MAVLink technologies.
Products
What we offer
Pilot AI: autonomous pilot
AI-assisted on-board software for autonomous navigation, decision-making and task execution by UAS and UGV platforms.
Mission Control: ground station
Multiplatform, multilingual, multi-robot mission planner, ready to work offline.
Post-mission analytics
Data collection, storage and analysis after each mission. In development.
UGV robots
Modular PX4 or ArduPilot unmanned ground vehicles.
Technology
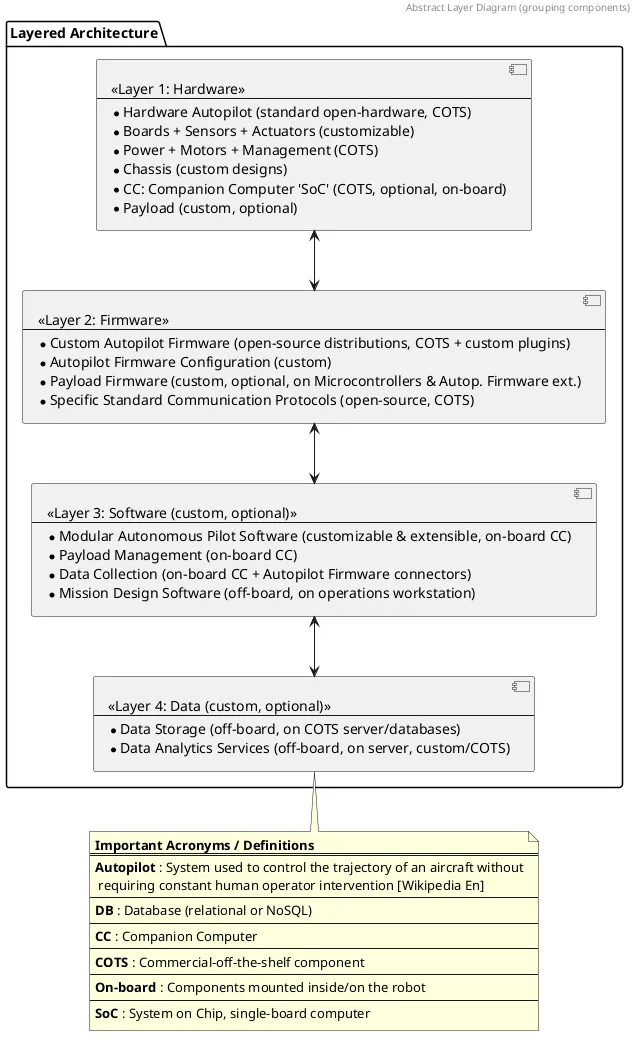
A layered, modular architecture
Every layer can be customised or replaced on its own. Commercial off-the-shelf (COTS) and open-hardware components where they are proven; custom designs where they add value.
Layer 1: Hardware
Open-hardware COTS autopilot · customisable boards, sensors and actuators · COTS power, motors and management · custom chassis designs · optional on-board companion computer (single-board computer) · optional custom payload.
Layer 2: Firmware
Open-source autopilot firmware distributions with custom plugins · custom autopilot configuration · optional payload firmware on microcontrollers and autopilot firmware extensions · standard open-source communication protocols.
Layer 3: Software
Modular, extensible autonomous pilot software, payload management and data collection on the companion computer · mission design software on the operations workstation.
Layer 4: Data (planned)
Off-board data storage on COTS servers and databases · data analytics services, custom or COTS. Not yet implemented.
Dual use
Use cases
Civilian
Agricultural monitoring, infrastructure inspection, security surveillance and patrolling.
Defence
Autonomous operations, patrolling, surveillance, and moving to an objective to perform a task. More tasks can be developed on demand.
See it working
Ask for a technical deep-dive or a demo of our autonomous rover and ground station.